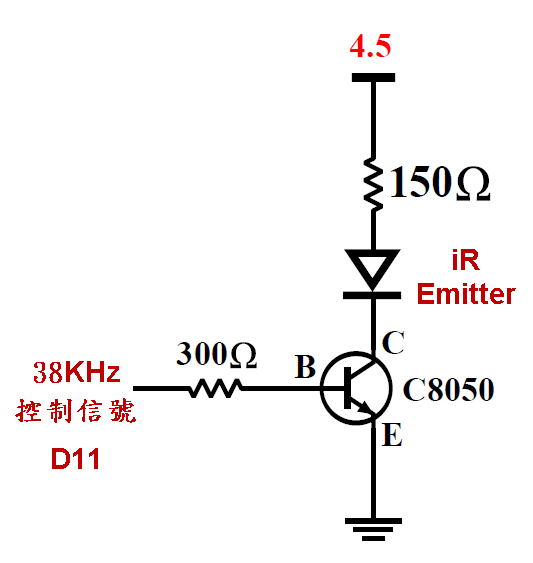
//38K, D11 should not be changed

// D11接150 Ohm電阻 接紅外線發射二極體之陽極,陰極接地

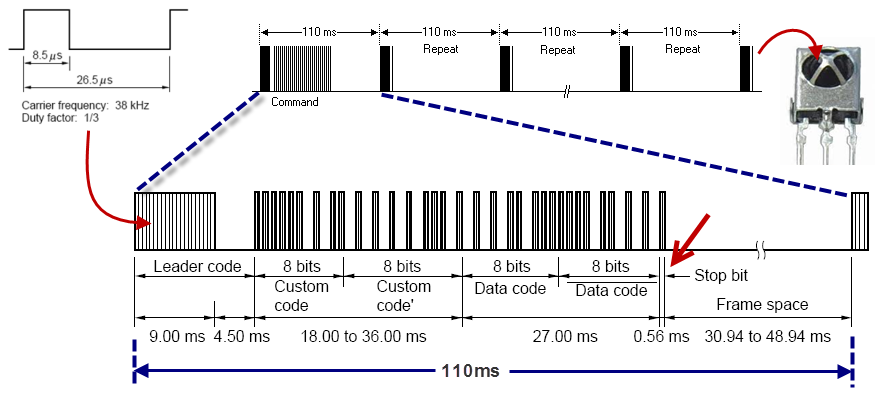
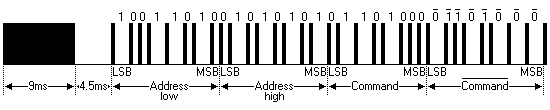
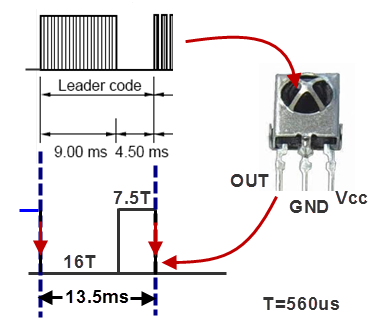
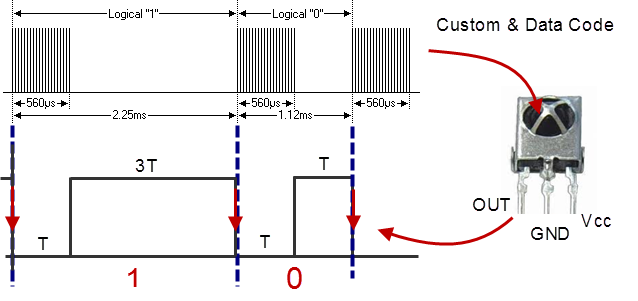
int T=560; //us
int T16=16*T;//9000
int T7p5=7.5*T;//4500
int T3=3*T;//1690
int i;

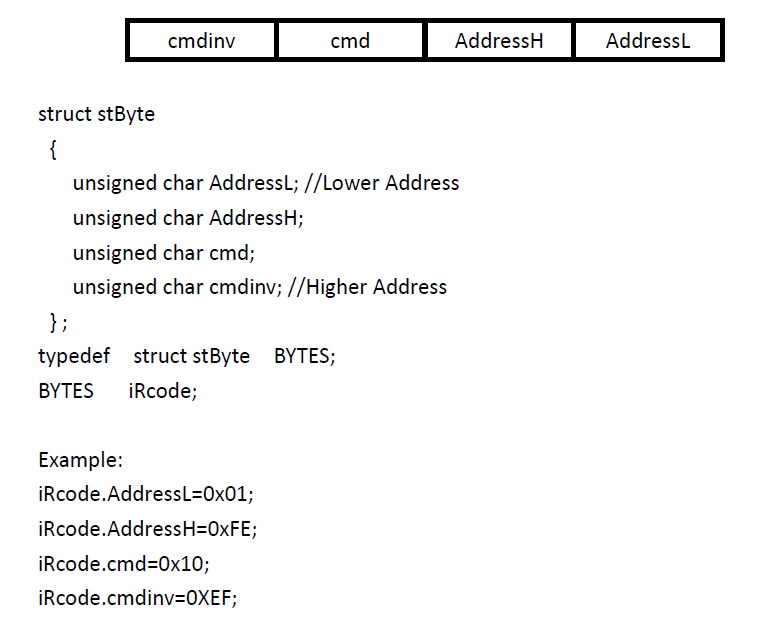
struct stByte
{
  unsigned char AddressL; //Lower Address
  unsigned char AddressH;
  unsigned char cmd;
  unsigned char cmdinv; //Higher Address
} ;

typedef struct stByte BYTES;
BYTES   iRcode;

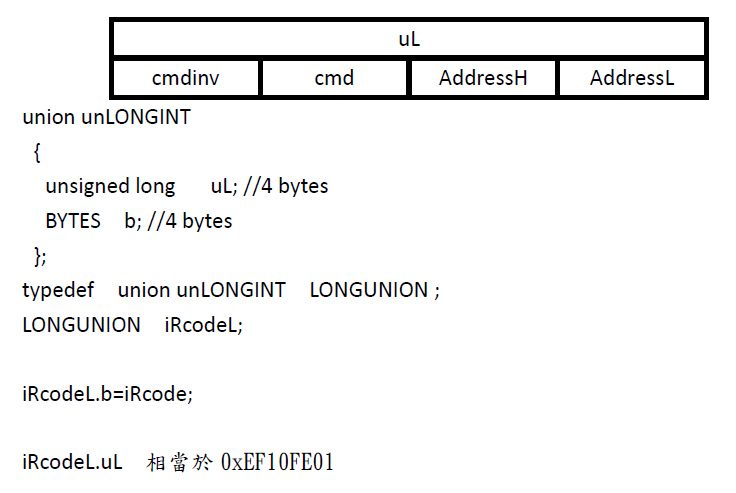
union unLONGINT
{
  unsigned long uL; //4 bytes
  BYTES b; //4 bytes
};
typedef union unLONGINT  LONGUNION ;
LONGUNION   iRcodeL;

void setup() {

  DDRB |=_BV(3); //pinMode(11,OUTPUT);
  TCCR2A &= (~_BV(COM2A1)) & (~_BV(WGM20));
  TCCR2A |= _BV(COM2A0) | _BV(WGM21);
  OCR2A=210;
  TCCR2B &=~_BV(WGM22) & ~_BV(CS22) & ~_BV(CS21);
  TCCR2B |= _BV(CS20);
  TCNT2=0;

}

void loop() {

  writeData(0xFE,0x01,0x10);
  delay(5000);
  writeData(0xFE,0x01,0x11);
  delay(5000);
}

void writeData(unsigned char aH,unsigned char aL,unsigned char keyC)
{
  iRcode.AddressH=aH;
  iRcode.AddressL=aL;
  iRcode.cmd=keyC;
  iRcode.cmdinv=~keyC;
  iRcodeL.b=iRcode;
  DDRB &=~_BV(3); //D11 input
  delay(10);

//sending leader code
   DDRB |=_BV(3); //38k D11 output
   delayMicroseconds(T16);
   DDRB &=~_BV(3); // D11 input, (38KHz is not sending out)
   delayMicroseconds(T7p5);

  for(i=0;i<32;i++)
    {
       DDRB |=_BV(3);//38k
       delayMicroseconds(T);
       DDRB &=~_BV(3); //D11 input
       if(iRcodeL.uL & 0x00000001) //1
         {
            delayMicroseconds(T3);
         }
       else
         {
            delayMicroseconds(T);
         }
       iRcodeL.uL=iRcodeL.uL>>1;
    }
//stop bit
    DDRB |=_BV(3);
    delayMicroseconds(T);
    DDRB &=~_BV(3);
}

T2_38Kfn2.zip


PDF DOCX


增加遙控距離


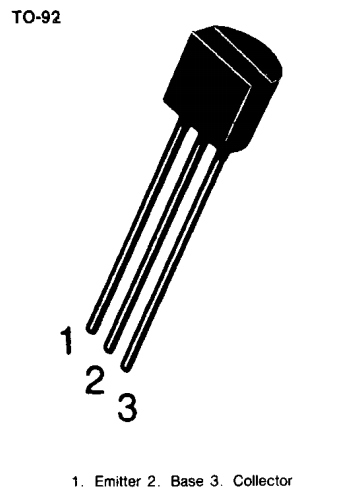
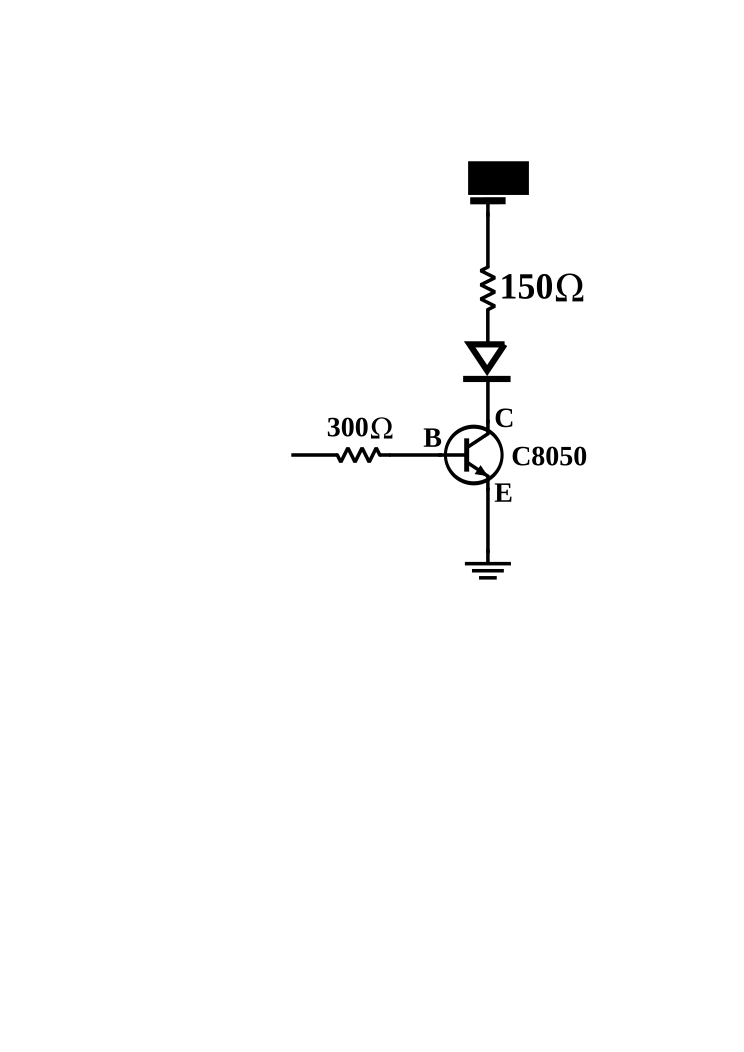
C8050 NPN

PDF SVG


D11:38KHz

D12:控制38KH輸出與否

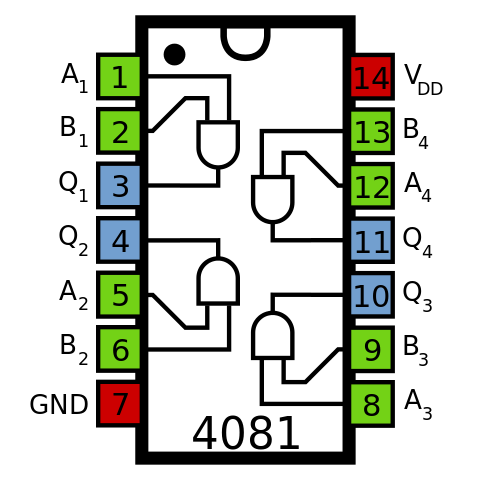
D11與D12接於AND Gate(4081)輸入

AND Gate 輸出接紅外線發射器


int T=560; //us
int T16=16*T;//9000
int T7p5=7.5*T;//4500
int T3=3*T;//1690
int i;

struct stByte
{
unsigned char AddressL; //Lower Address
unsigned char AddressH;
unsigned char cmd;
unsigned char cmdinv; //Higher Address
} ;

typedef struct stByte BYTES;
BYTES iRcode;

union unLONGINT
{
unsigned long uL; //4 bytes
BYTES b; //4 bytes
};
typedef union unLONGINT LONGUNION ;
LONGUNION iRcodeL;

void setup() {

    pinMode(11,OUTPUT); //38K, D11 should not be changed
    pinMode(12,OUTPUT); //Control pin

    DDRB |=_BV(3);
    TCCR2A &= (~_BV(COM2A1)) & (~_BV(WGM20));
    TCCR2A |= _BV(COM2A0) | _BV(WGM21);
    OCR2A=210;
    TCCR2B &=~_BV(WGM22) & ~_BV(CS22) & ~_BV(CS21);
    TCCR2B |= _BV(CS20);
    TCNT2=0;

}

void loop() {

   writeData(0xFE,0x01,0x10);
   delay(5000);
   writeData(0xFE,0x01,0x11);
   delay(5000);
}

void writeData(unsigned char aH,unsigned char aL,unsigned char keyC)
{
   iRcode.AddressH=aH;
   iRcode.AddressL=aL;
   iRcode.cmd=keyC;
   iRcode.cmdinv=~keyC;
   iRcodeL.b=iRcode;
   PORTB &=~_BV(4); //D12
   delay(10);

   //sending leader code
   PORTB |=_BV(4); //38k
   delayMicroseconds(T16);
   PORTB &=~_BV(4); // low
   delayMicroseconds(T7p5);

  //sending address and data

   for(i=0;i<32;i++)
    {
       PORTB |=_BV(4);//passing through 38KHz signal
       delayMicroseconds(T);
       PORTB &=~_BV(4); //low
       if(iRcodeL.uL & 0x00000001) //1
         {
            delayMicroseconds(T3);
          }
      else
         {
            delayMicroseconds(T);
         }
      iRcodeL.uL=iRcodeL.uL>>1;
    }
//stop bit
    PORTB |=_BV(4);
    delayMicroseconds(T);
    PORTB &=~_BV(4); //D12
}

source code