例題 4Example 4
題目 Problem
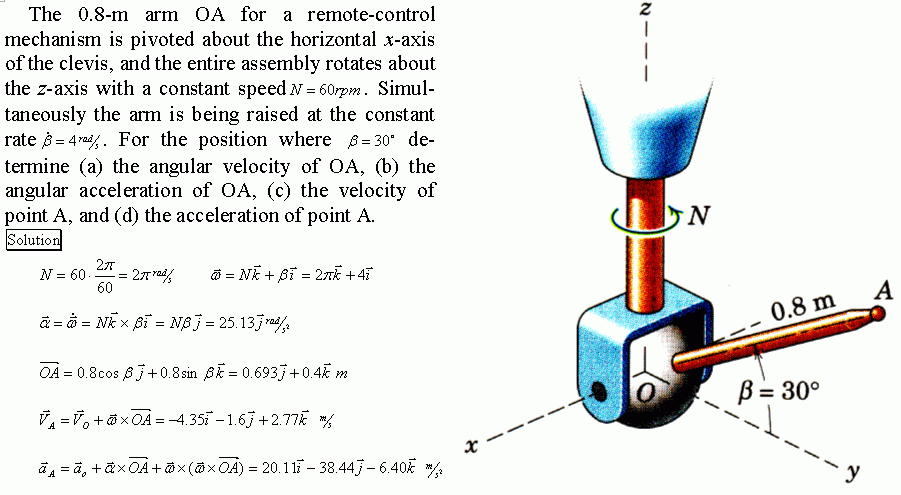
The 0.8-m arm OA for a remote-control mechanism is pivoted about the horizontal \(x\)-axis of the clevis, and the entire assembly rotates about the \(z\)-axis with a constant speed \(N = 60\ \text{rpm}\). Simultaneously the arm is being raised at the constant rate \(\dot\beta = 4\ \text{rad/s}\). For the position where \(\beta = 30^\circ\) determine
- the angular velocity of OA,
- the angular acceleration of OA,
- the velocity of point A, and
- the acceleration of point A.
解答 Solution
$$N = 60\cdot\frac{2\pi}{60} = 2\pi\ \text{rad/s} \qquad \vec\omega = N\vec k + \dot\beta\,\vec i = 2\pi\vec k + 4\vec i$$
$$\vec\alpha = \dot{\vec\omega} = N\vec k\times\dot\beta\,\vec i = N\dot\beta\,\vec j = 25.13\,\vec j\ \ \text{rad/s}^2$$
$$\overrightarrow{OA} = 0.8\cos\beta\,\vec j + 0.8\sin\beta\,\vec k = 0.693\,\vec j + 0.4\,\vec k\ \ \text{m}$$
$$\vec V_A = \vec V_O + \vec\omega\times\overrightarrow{OA} = -4.35\,\vec i - 1.6\,\vec j + 2.77\,\vec k\ \ \text{m/s}$$
$$\begin{aligned}
\vec a_A &= \vec a_O + \vec\alpha\times\overrightarrow{OA} + \vec\omega\times\left(\vec\omega\times\overrightarrow{OA}\right) \\
&= 20.11\,\vec i - 38.44\,\vec j - 6.40\,\vec k\ \ \text{m/s}^2
\end{aligned}$$
- \(O\) 點不動,所以 \(\vec V_O = \vec 0\)、\(\vec a_O = \vec 0\)。
對照原始圖檔